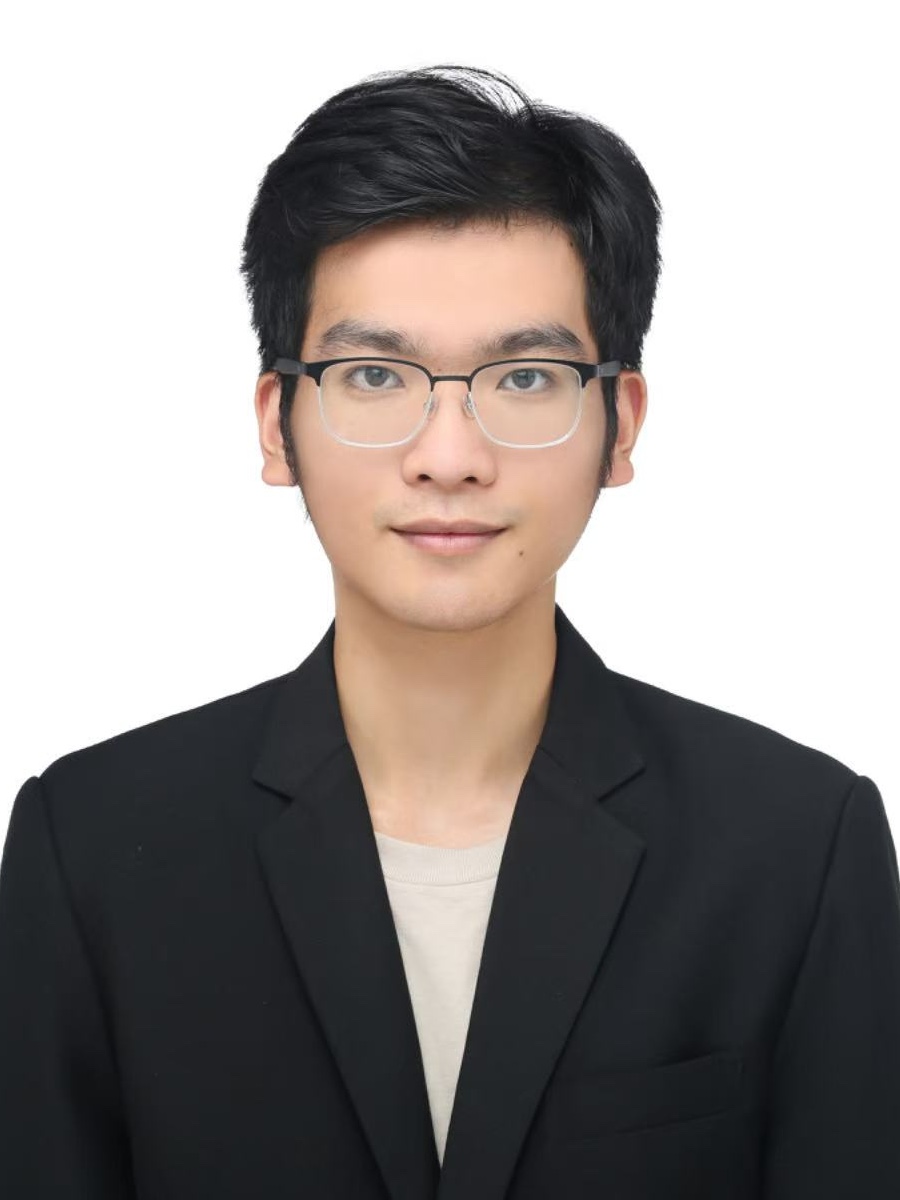
Zhuoyuan Yu is an undergraduate student in the Class of 2024 at the School of Electronics Engineering and Computer Science. Under the supervision of Professor Wenxin Li, his research focuses on embodied robotics, including locomotion control, dexterous hand manipulation, and vision-language navigation.
publication:
1. CorrectNav: Self-Correction Flywheel Empowers Vision-Language-Action Navigation Model
2. NavSpace: How Navigation Agents Follow Spatial Intelligence Instructions
3. One Scan is Enough: Demonstration-Free Adaptation for Language-Guided Navigation
4. Qwen-RobotNav: A Scalable Navigation Model Designed for an Agentic Navigation System